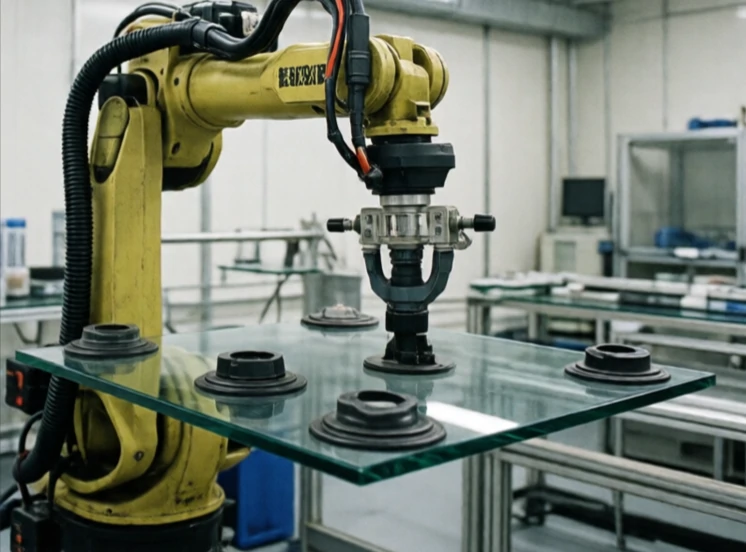
The end effector is the device at the end of a robot arm that interacts with the world. It is the hand, the tool, the gripper, the welding torch, the suction cup. The arm positions it. The end effector does the work.
End effectors are task-specific. A robot that picks up boxes might use a vacuum gripper. A robot that welds uses a torch. A robot that assembles electronics uses a tiny gripper with force sensing. Changing the end effector changes what the robot can do, which is why quick-change couplings are common in flexible manufacturing.
Common end effector types
- Two-finger gripper: simple, versatile, widely used.
- Vacuum gripper: flat surfaces, cardboard, glass.
- Magnetic gripper: ferrous metal parts.
- Welding torch: joined to the arm, precise path control.
- Force/torque sensor: measures contact for assembly.
The end effector is where accuracy, repeatability, and dexterity meet the real world. A perfect robot arm with a poor gripper fails the task. A simple arm with a well-designed end effector can outperform expectations. Tool changers let one robot perform multiple tasks by swapping end effectors automatically. Sensors in the end effector provide feedback: did the gripper close on the part? Is the force too high? That feedback closes the loop and makes the robot reliable. The end effector is the business end of the robot, and it deserves as much design attention as the arm itself.
Comments
No comments yet. Be the first to share a thought.
Leave a comment