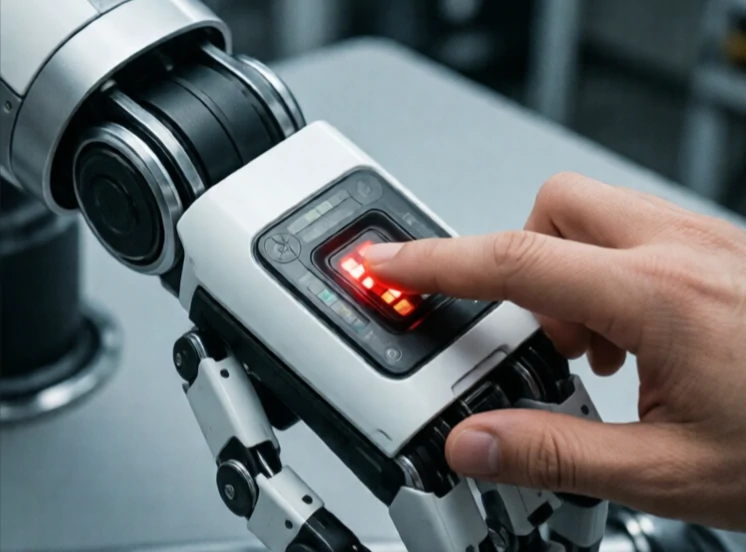
Collision detection is how a robot knows it has hit something. A bumper switch clicks. A force sensor measures a spike. A motor current reading jumps when the arm stalls. The signal tells the controller to stop, back up, or change strategy.
In simulation, collision detection is mathematical. Algorithms check whether 3D models intersect. In the real world, it is physical. Contact sensors, strain gauges, and accelerometers detect impact. Some robots use motor current as a proxy for force: when the current rises unexpectedly, the robot infers contact.
Collision detection methods
- Contact switches: simple, binary, cheap.
- Force/torque sensors: measure direction and magnitude.
- Motor current monitoring: no extra hardware, less precise.
- Skin sensors: capacitive or piezoelectric arrays covering the robot body.
- Vision-based: detect unexpected object proximity before contact.
Detection speed matters. A robot moving fast needs to detect contact in milliseconds to avoid damage. A gentle cobot can afford to be slower. Some systems distinguish between expected contact, like grasping an object, and unexpected contact, like hitting a wall. That distinction prevents the robot from dropping a part every time it touches something. Collision detection is the sense of touch for machines. Without it, robots are blind and clumsy. With it, they can work in cluttered, human-filled spaces.
Comments
No comments yet. Be the first to share a thought.
Leave a comment