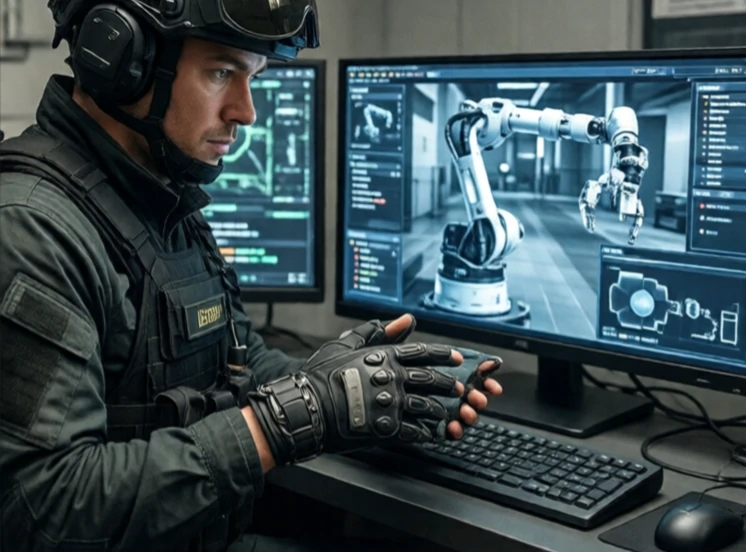
Haptic feedback provides touch sensations to a robot operator. It lets a surgeon feel tissue resistance during robotic surgery. It lets a bomb disposal technician feel the weight of an object. It lets a drone pilot feel the wind. Without haptics, the operator is working blind, relying only on vision.
The technology works by measuring forces at the robot's end effector and reproducing them at the operator's controls. A force sensor at the robot's wrist sends signals to motors in a joystick or glove. The operator feels resistance, vibration, or texture. Latency must be low, or the sensation feels wrong and can cause instability.
Types of haptic feedback
- Force feedback: resistance to motion.
- Vibrotactile: vibration patterns.
- Texture simulation: high-frequency vibration.
- Thermal: temperature changes, less common.
- Kinesthetic: whole-arm force and position feedback.
Haptic feedback is common in surgical robots like the da Vinci system, where surgeons need to feel how hard they are pulling or cutting. It is also used in teleoperated robots for nuclear cleanup and deep-sea exploration. Consumer devices use haptics for gaming and virtual reality. The challenge is range and fidelity. A haptic device that can simulate a feather touch and a sledgehammer blow is hard to build. Most systems optimize for a specific force range. Haptics closes the loop between human and robot, making teleoperation feel less like remote control and more like being there.
Comments
No comments yet. Be the first to share a thought.
Leave a comment