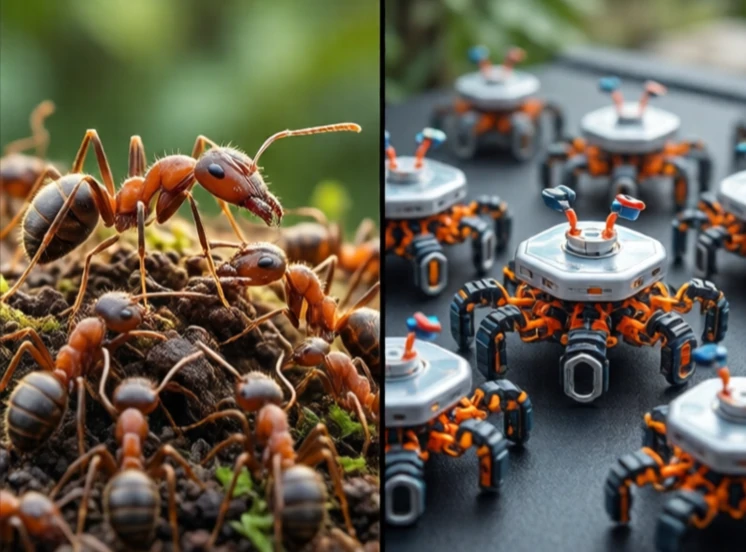
Swarm robotics coordinates many simple robots to perform a task collectively. Each robot is cheap and limited. Together they achieve things a single robot cannot. The inspiration comes from ants, bees, and termites. No single insect is smart. The colony is.
Swarm robots follow simple rules. Separate to avoid collisions. Align to match neighbors. Cohere to stay together. From these local rules, global behavior emerges. The swarm can form shapes, transport large objects, or cover an area for search and rescue. No central controller. No leader. Just local interactions.
Swarm robotics principles
- Decentralization: no single point of failure.
- Scalability: add more robots without reprogramming.
- Robustness: losing a few robots does not stop the swarm.
- Simplicity: each robot has limited sensing and computation.
- Emergence: complex behavior from simple rules.
Swarm robotics is mostly research. Real-world applications are emerging: agricultural robots that monitor fields, warehouse robots that move shelves, and underwater robots that map the ocean floor. The challenges are communication, coordination, and hardware. Robots need to talk to each other without a central hub. They need to avoid collisions in dense groups. They need to be cheap enough to deploy in large numbers. A swarm of a thousand robots is impressive in a lab. A swarm of a million is the long-term goal. It would change how we think about construction, exploration, and environmental monitoring. The whole is greater than the sum of its parts.
Comments
No comments yet. Be the first to share a thought.
Leave a comment