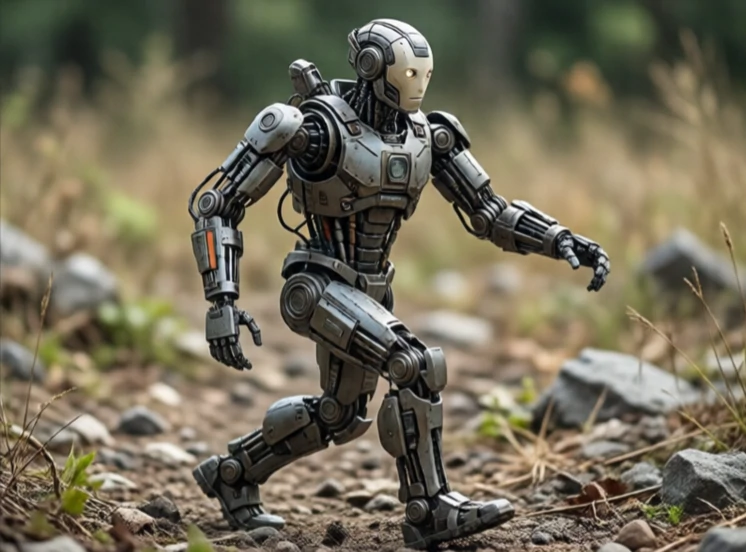
A legged robot moves on mechanical legs instead of wheels or tracks. Legs handle terrain that wheels cannot: stairs, rocks, mud, and rubble. The trade-off is complexity. A wheeled robot is stable by default. A legged robot must actively balance with every step.
Research in legged locomotion took off in the 1980s with Raibert's hopping machines at MIT. Honda's ASIMO and Sony's AIBO followed. Boston Dynamics' BigDog, Spot, and Atlas pushed dynamic movement further, and Spot is now commercially available for inspection and patrol work. The control problem is hard because the robot is unstable and the ground is unpredictable.
Legged robot types
- Biped: two legs, human-like, hard to balance.
- Quadruped: four legs, stable, popular for rough terrain.
- Hexapod: six legs, very stable, slow.
- Hybrid: wheels on legs, combines speed and climbing.
- Hopper: one leg, research platform for dynamics.
Legged robots excel where the ground is not flat. They can step over obstacles, climb stairs, and recover from pushes. They are slower and less efficient than wheeled robots on smooth surfaces. The control challenge is immense. Every step is a controlled fall. The robot must plan foot placement, maintain balance, and adapt to slipping or unexpected contact. Advances in model predictive control and reinforcement learning have made legged robots dramatically better in the last decade. They are not yet as common as wheeled robots, but they go places wheels cannot.
Comments
No comments yet. Be the first to share a thought.
Leave a comment