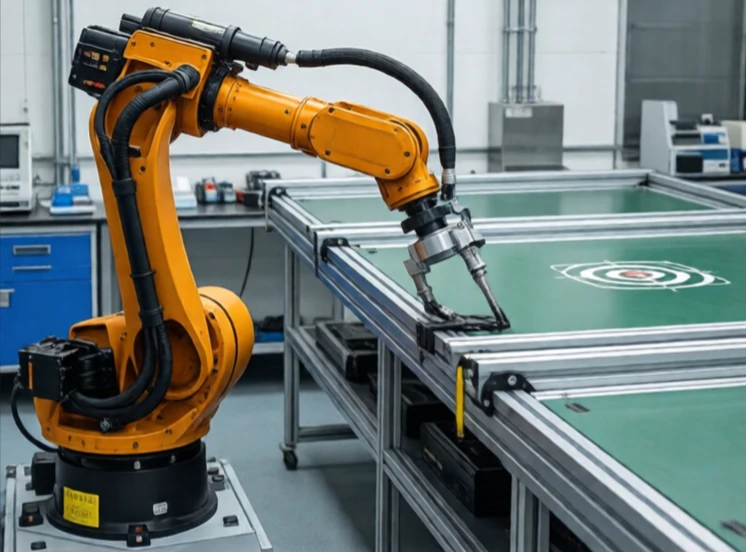
Workspace is the volume a robot can reach with its end effector. It is the three-dimensional space where the robot can do work. Anything outside the workspace is unreachable. Anything inside may be reachable in one orientation but not another.
The workspace depends on the robot's geometry. A Cartesian robot has a rectangular workspace. A SCARA robot has a cylindrical workspace. An articulated robot has a complex, irregular workspace shaped like a blob. The workspace also depends on the joint limits. A joint that cannot rotate past 180 degrees cuts the workspace in half.
Workspace considerations
- Reachable workspace: all points the robot can touch.
- Dexterous workspace: points the robot can reach in any orientation.
- Joint limits reduce the workspace.
- Singularities create holes in the workspace.
- Obstacles and self-collision further restrict it.
Workspace is a critical specification when selecting a robot. A robot with a large workspace can cover a big area. A robot with a small workspace must be mounted close to the task. The shape of the workspace matters as much as the size. A spherical workspace is useful for reaching around obstacles. A rectangular workspace is useful for linear tasks. Engineers plot the workspace in simulation to check that the robot can reach every point it needs to. If a point is just outside the workspace, the robot will stretch to its limit and lose precision. If it is deep inside, the robot has margin. Workspace is the robot's reach. It defines what is possible and what is not.
Comments
No comments yet. Be the first to share a thought.
Leave a comment