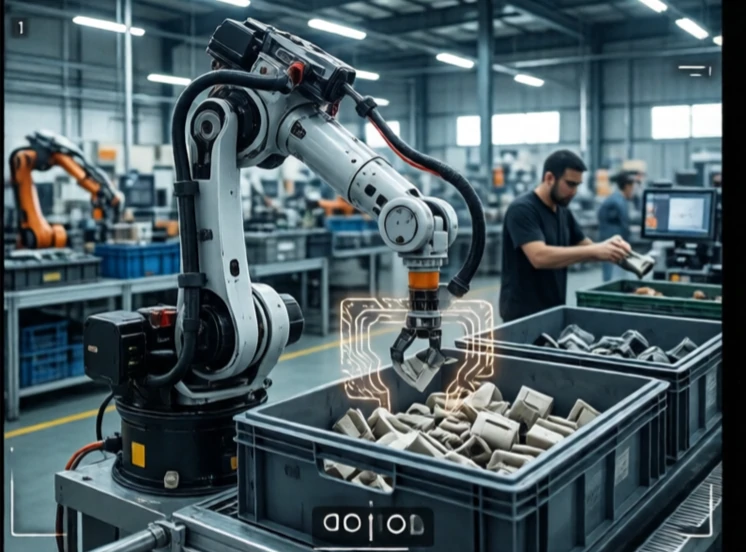
Object recognition identifies what is in an image or sensor scan. Is that a person, a car, a coffee cup, a defect? The robot needs to know what it is looking at before it can decide what to do. Recognition is the first step in perception.
Early systems used hand-crafted features: edges, corners, textures. They worked for specific objects in controlled lighting. Deep learning changed everything. Convolutional neural networks learn features from labeled data. A network trained on millions of images can recognize thousands of object categories with superhuman accuracy on benchmark tests. In the real world, performance drops when lighting changes, objects overlap, or the camera moves.
Object recognition tasks
- Classification: what is in the image?
- Detection: where is it, and what is it?
- Segmentation: which pixels belong to the object?
- Pose estimation: how is it oriented?
- Tracking: where does it move over time?
A robot might use recognition to pick a specific part from a bin, avoid a pedestrian, or inspect a weld for defects. The challenge is generalization. A network trained on sunny daylight images may fail at night. A network trained on one factory's parts may fail on another's. Data collection and augmentation are as important as the model architecture. The best systems combine deep learning with geometric reasoning and sensor fusion. A camera might recognize the object. Lidar confirms its position. Force sensors confirm the grasp. Recognition is not just about seeing. It is about understanding what the robot needs to know.
Comments
No comments yet. Be the first to share a thought.
Leave a comment