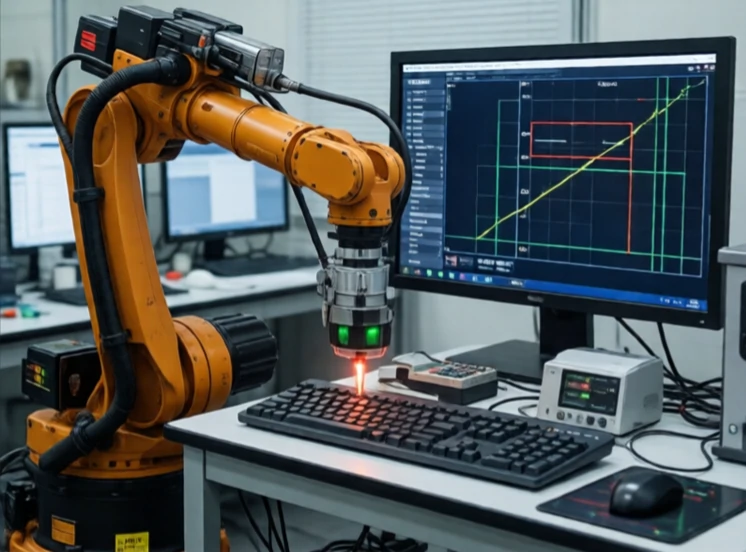
A sensor detects a physical property and converts it into a signal. Temperature, pressure, distance, light, sound, acceleration, magnetic field: if it can be measured, there is a sensor for it. Robots use sensors to perceive the world. Without sensors, a robot is blind, deaf, and numb.
Sensors come in many forms. A thermocouple converts temperature difference into voltage. A photodiode converts light into current. An accelerometer converts acceleration into a change in capacitance. A lidar converts time-of-flight into distance. Each sensor has a range, a resolution, an accuracy, and a bandwidth. Choosing the right sensor means matching those specifications to the task.
Sensor characteristics
- Range: minimum and maximum measurable value.
- Resolution: smallest detectable change.
- Accuracy: closeness to the true value.
- Precision: repeatability of measurements.
- Bandwidth: how fast the sensor responds.
Sensors are never perfect. They have noise, drift, and nonlinearity. They can be affected by temperature, humidity, and electromagnetic interference. Calibration corrects systematic errors. Filtering reduces noise. Fusion combines multiple sensors to compensate for individual weaknesses. A robot might use a camera, lidar, IMU, and wheel encoders together to estimate its position. No single sensor is enough. The art of sensor selection is understanding what each sensor does well and what it does poorly. A cheap sensor with good fusion can outperform an expensive sensor used alone. The sensor is the robot's connection to reality. If it lies, the robot makes bad decisions.
Comments (3)
Leave a comment